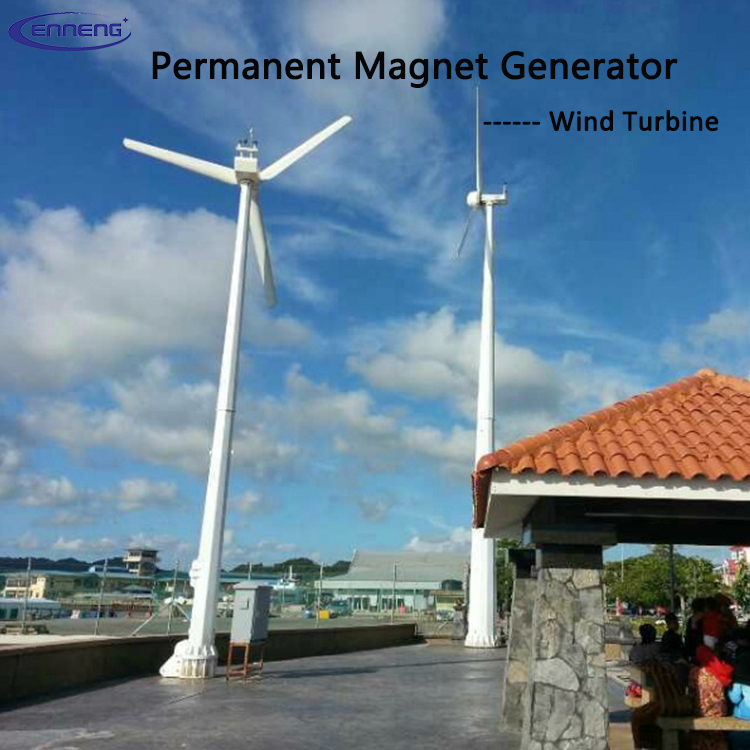
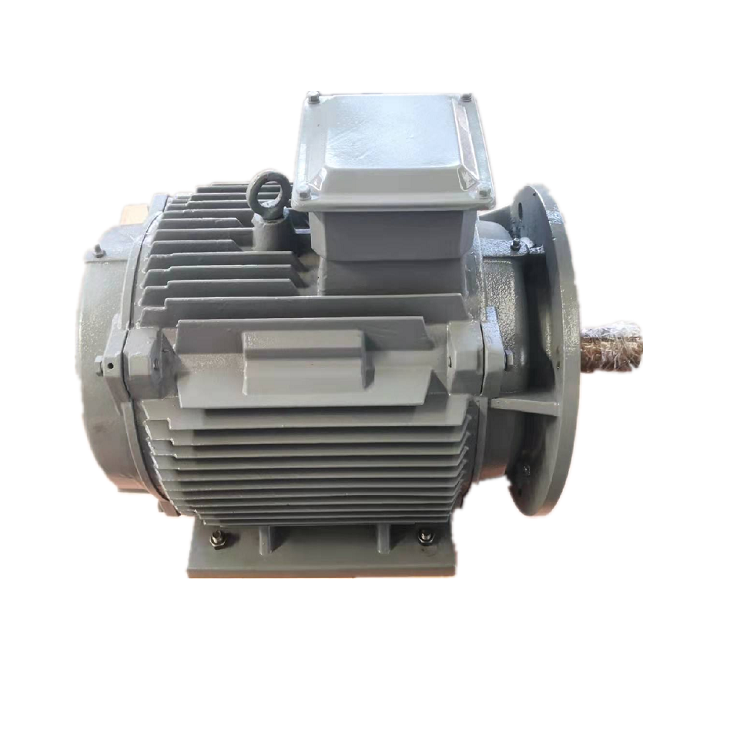
Specify mechanical input and electrical output together
A permanent magnet generator inquiry needs both sides of the energy conversion boundary. On the mechanical side, define shaft speed range, continuous and transient torque, direction, overspeed, inertia and the prime mover. On the electrical side, define rated power, voltage, phase arrangement, frequency requirement, load type, rectification, converter and grid or storage interface. A power value without speed does not establish torque, and a voltage value without speed and winding context does not establish a generator design.
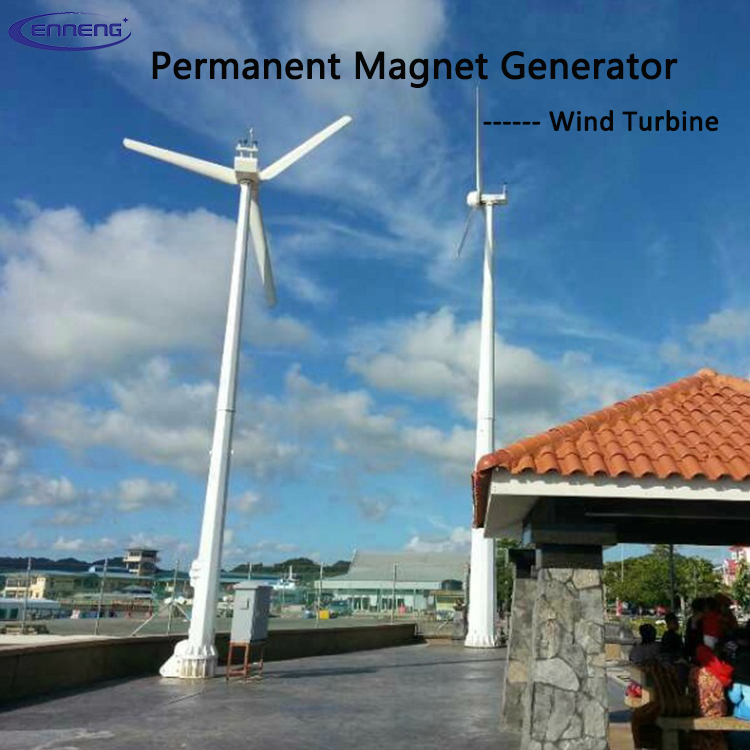
Describe the complete operating envelope rather than one rated point. Wind, hydro and engine-driven systems may spend substantial time away from nominal speed. The electrical interface may regulate voltage or DC-link conditions while mechanical input varies. These control responsibilities should be identified early so the generator, converter and supervisory control are designed as a coordinated system.
Speed, voltage and frequency are linked
For a synchronous machine, electrical frequency follows rotational speed and pole count. If a project requires fixed grid frequency while the prime mover operates over a variable speed range, power electronics usually decouple generator frequency from grid frequency. NREL describes full-converter wind turbine models in which the converter handles the generator output and controls the grid interface. The converter architecture is therefore a core selection input, not an accessory chosen at the end.
State whether the desired output is variable-frequency AC, regulated AC, rectified DC or a DC link feeding an inverter. Include voltage range, current, power factor or DC-load behavior and fault expectations. For battery charging or isolated loads, describe the downstream regulation and protection. This prevents a winding optimized for one interface from being proposed for a different electrical system.
Cogging, starting and low-speed behavior
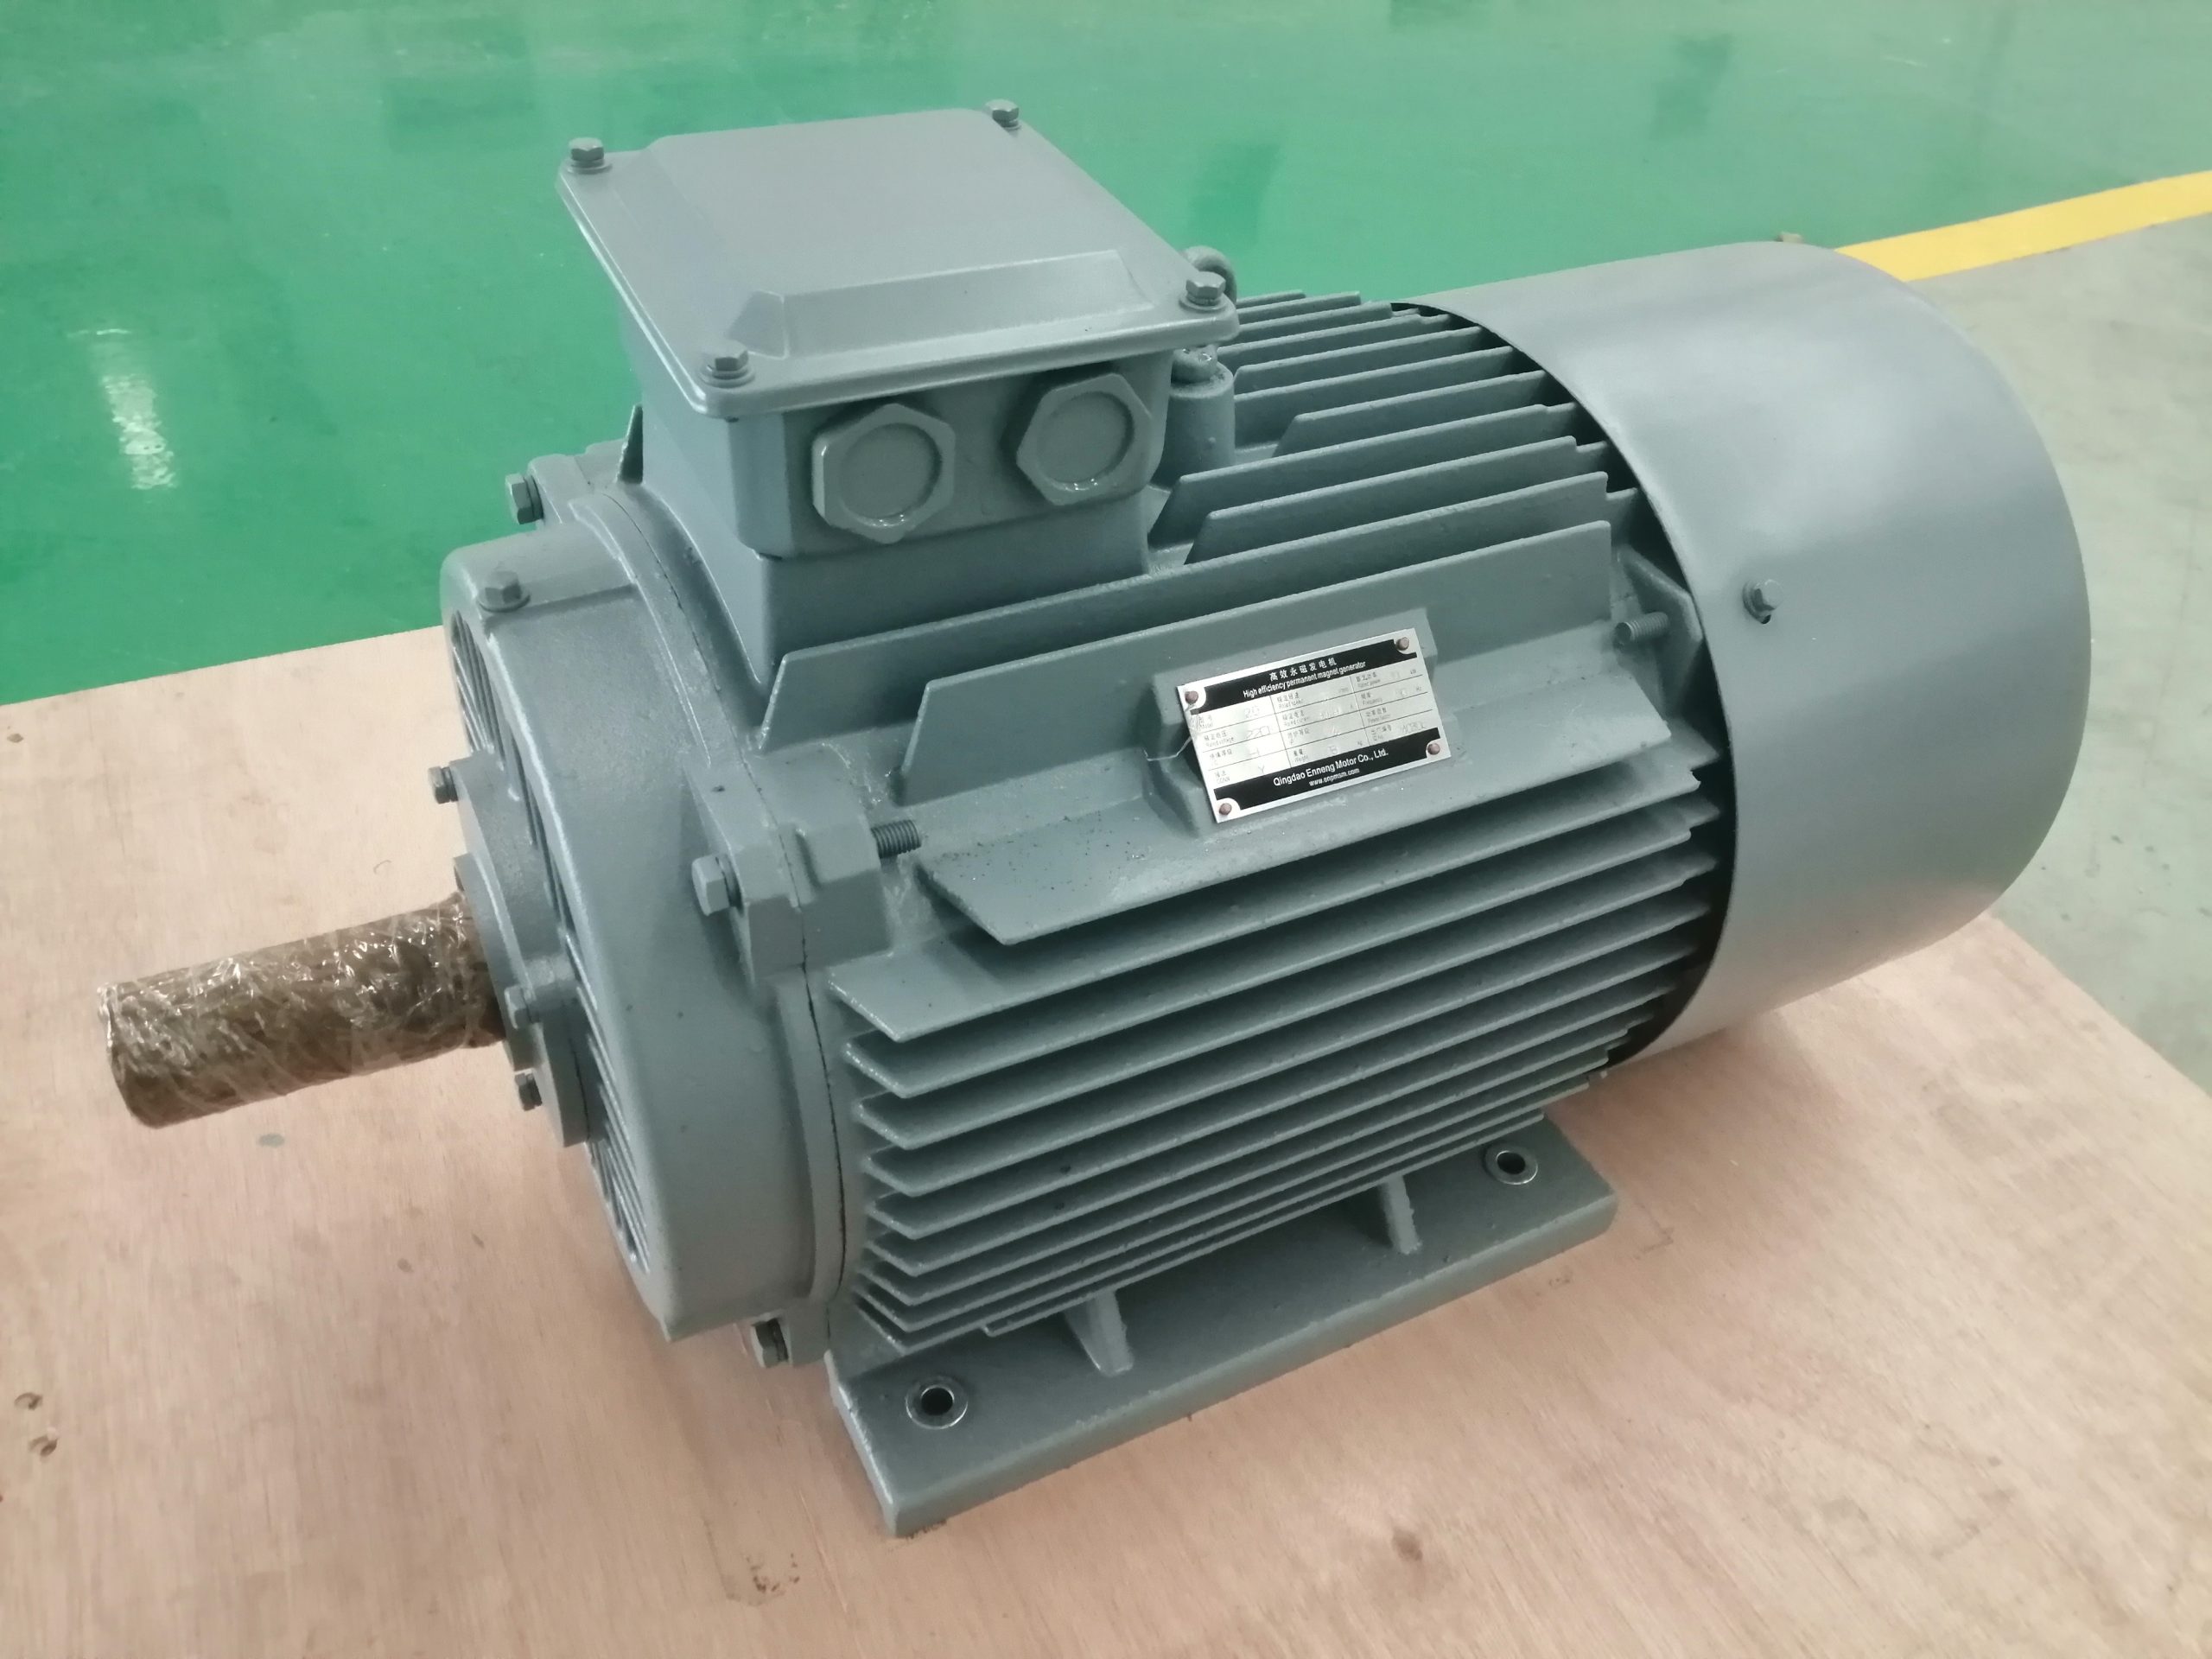
Permanent magnet machines can exhibit cogging torque due to the interaction between rotor magnets and stator slotting. NREL research on advanced PM generator topologies identifies cogging torque as a design concern because it can affect self-start behavior, noise and performance in small wind systems. The importance of cogging depends on the prime mover, inertia, starting torque and control architecture.
If self-starting at low input torque matters, provide the prime-mover torque-speed curve and minimum useful speed. If the generator is driven by an engine or controlled turbine with ample starting torque, priorities may differ. Describe permissible torque ripple, noise and vibration so these factors can be evaluated against the actual application rather than treated as universal pass-fail labels.
PMG request-for-quotation package
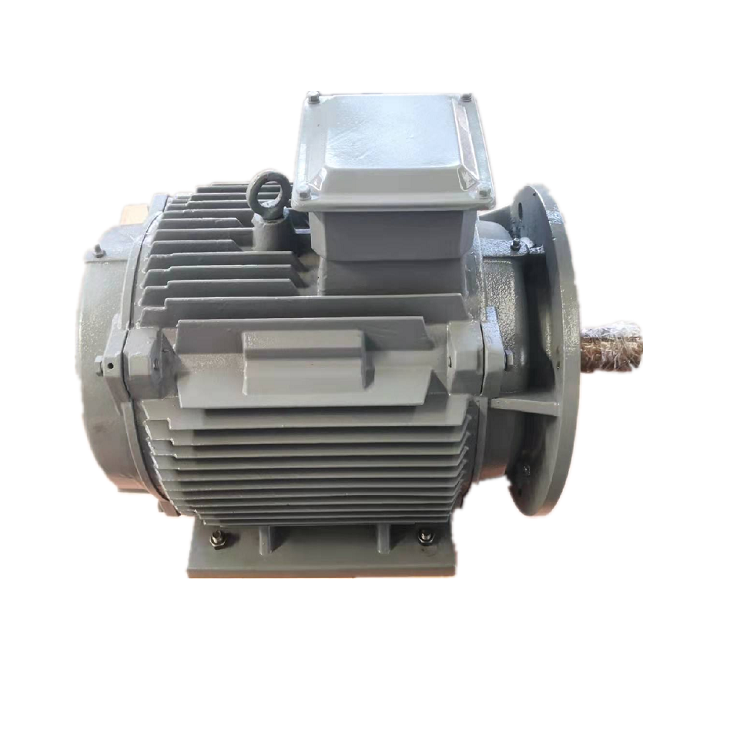
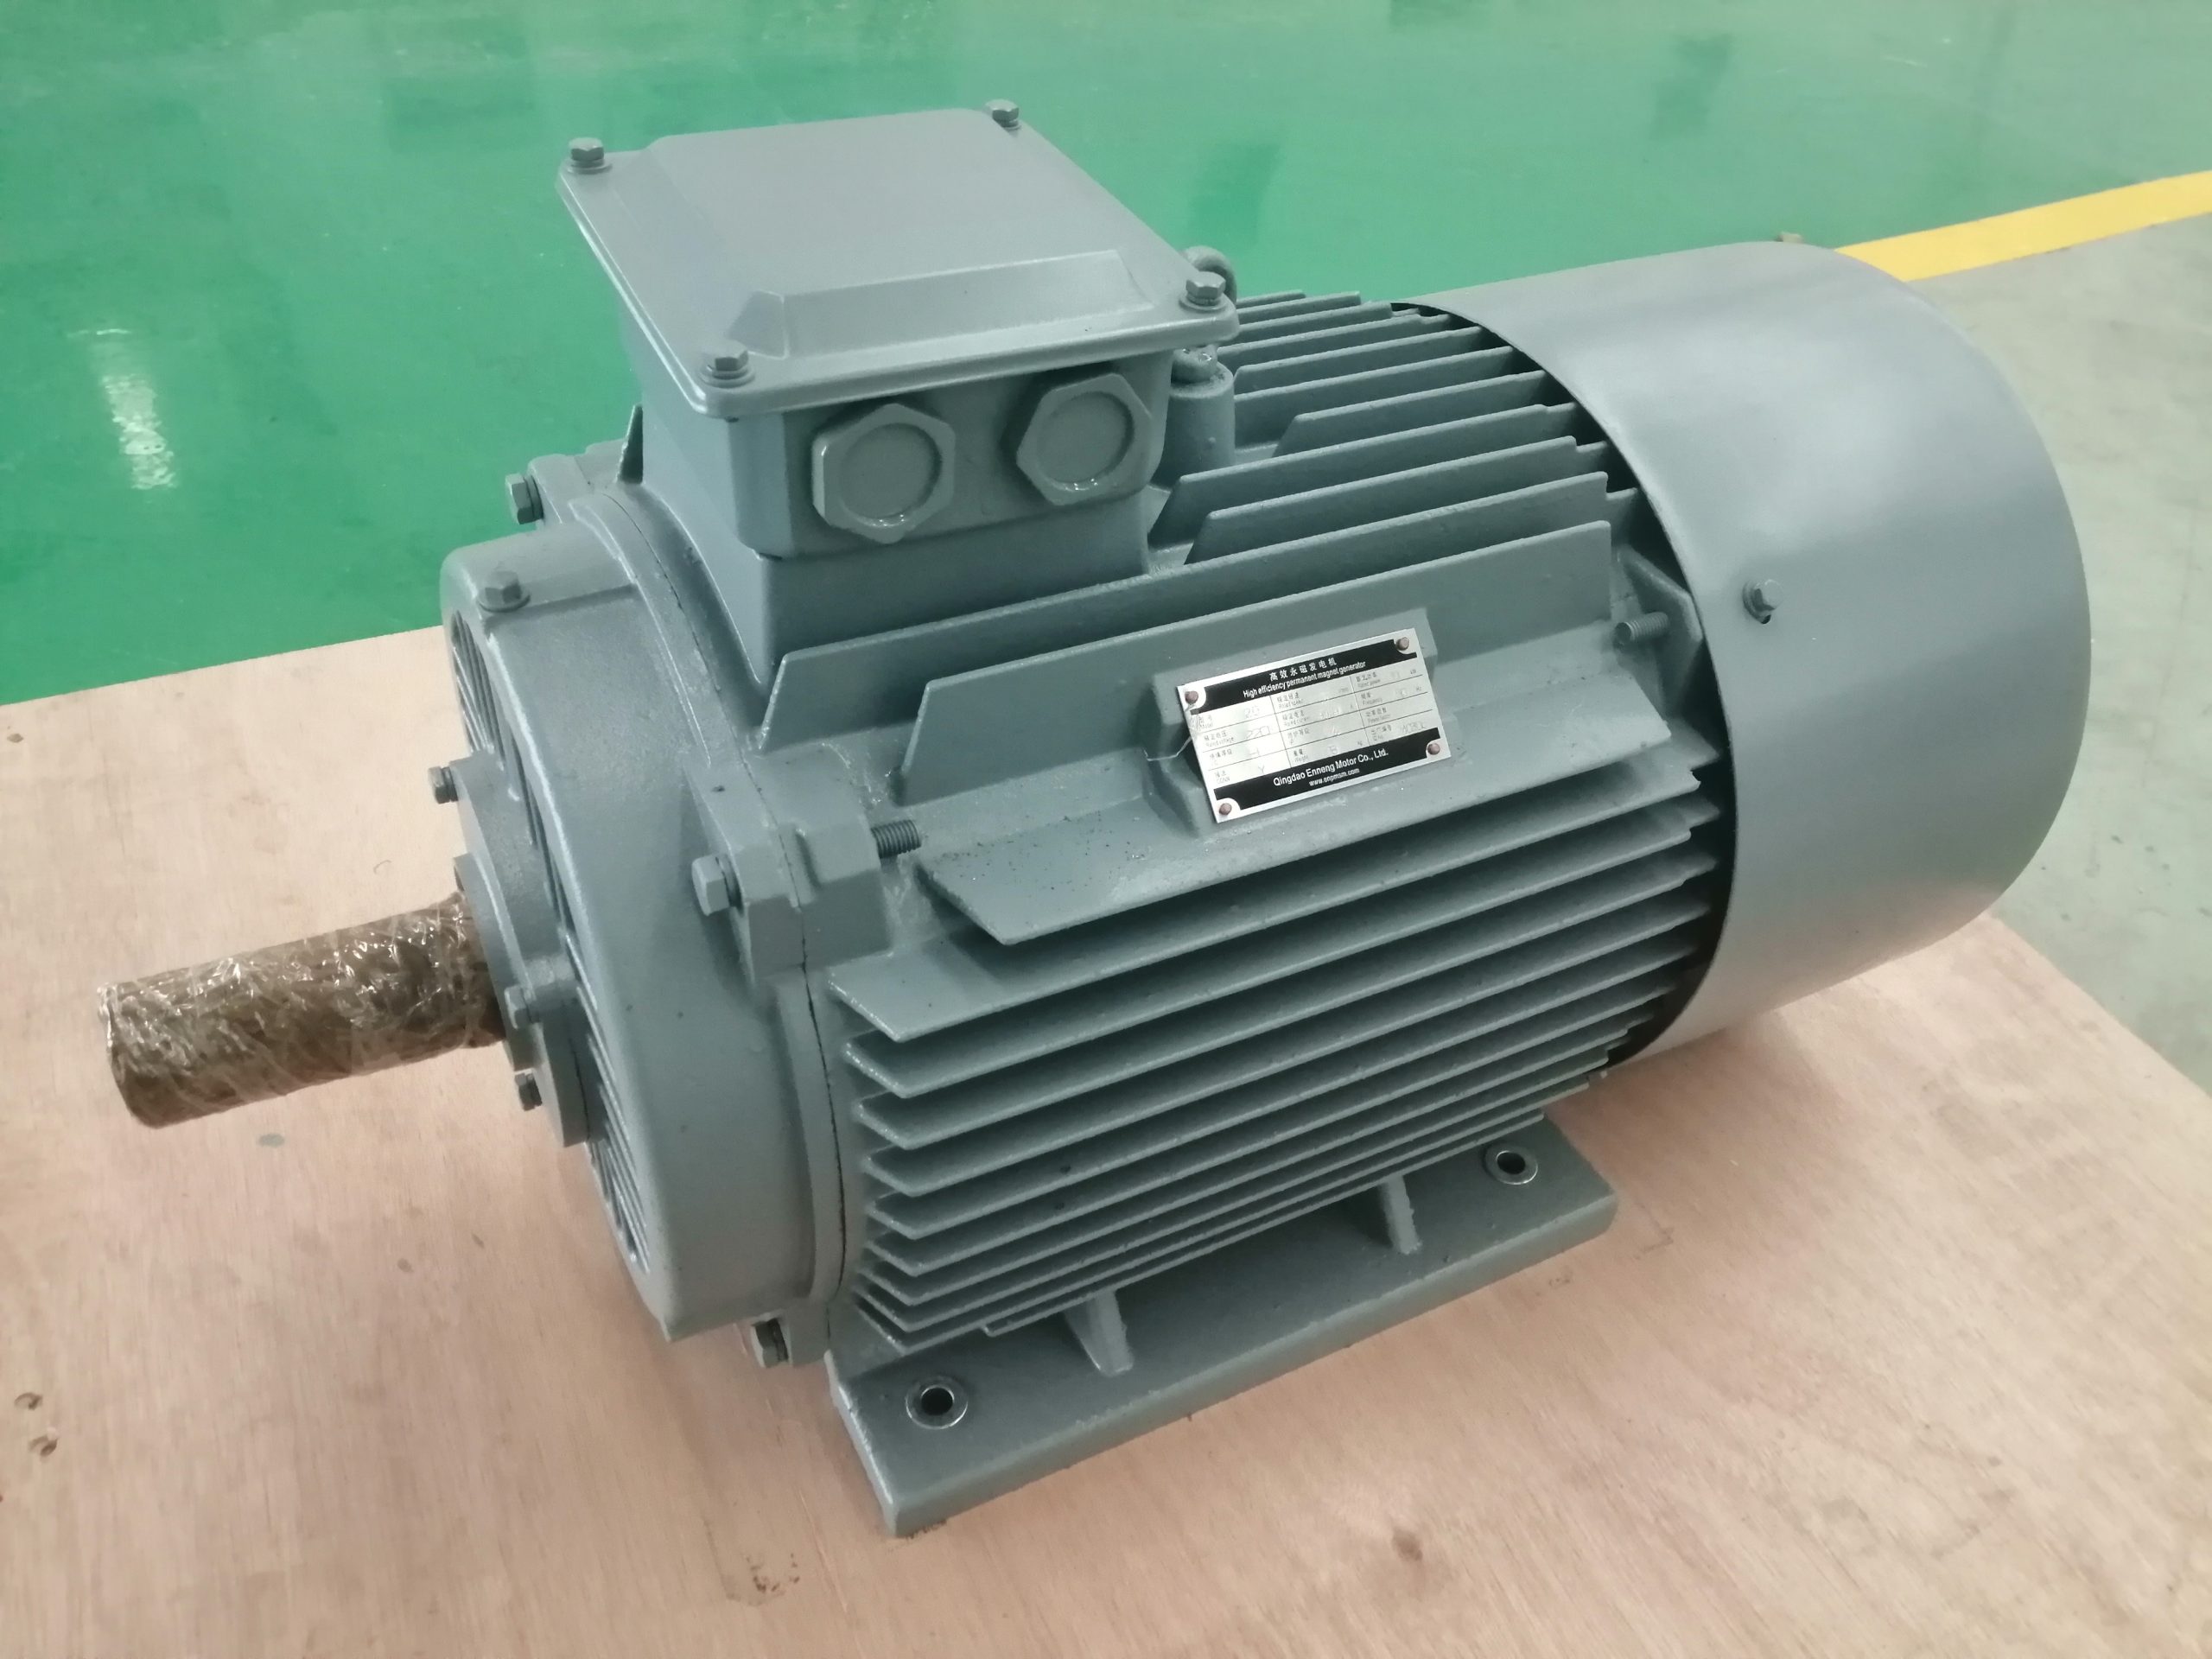
Provide rated and maximum power, nominal and full speed range, continuous and transient torque, desired voltage and phase arrangement, frequency or DC-link requirement, converter details, load type, duty cycle, cooling, environment, overspeed, mounting, shaft and coupling information, allowable envelope and required sensors. Add the prime-mover curve where available.
Mark which values are fixed and which can be optimized. If the project is at concept stage, state the uncertainty range rather than inventing a precise point. ENNENG can then identify feasible directions and the calculations or tests needed next. This creates a technical record that can support design review, quotation and later acceptance planning.